How to Choose a UR Robot Arm for Your Application?
Choosing a UR robot arm is not simply a matter of comparing payload figures. The right model must fit your process, workspace, people, and production goals. A compact assembly cell needs different capabilities than a palletizing line or machine-tending station. Small details matter. A heavy gripper can reduce useful payload. A crowded workbench can limit reach. A fast robot may still underperform when the end-of-arm tool changes slowly.
Universal Robots co-founder Esben Østergaard has said, “The future of robotics is not about replacing humans, but about augmenting human capabilities.” This idea remains practical on the factory floor. A suitable UR robot arm should support operators, simplify repetitive work, and integrate safely beside them. Buyers should examine payload, reach, repeatability, cycle time, mounting options, software compatibility, and safety requirements. They should also check whether technicians can program and maintain the system without constant outside support.
No selection process is perfect. In practice, teams sometimes choose the largest arm, expecting flexibility, but create unnecessary cost and slower motion. Others focus on purchase price and overlook tooling, installation, training, and downtime. A better evaluation uses real parts, actual cycle targets, and a representative workspace test. Measure the load at full extension. Test cable routing. Let operators try the interface. The answer may not be the most powerful model. It may be the one that works reliably every shift, with fewer compromises.
Define Payload Needs Using UR3e–UR30 Capacity Data
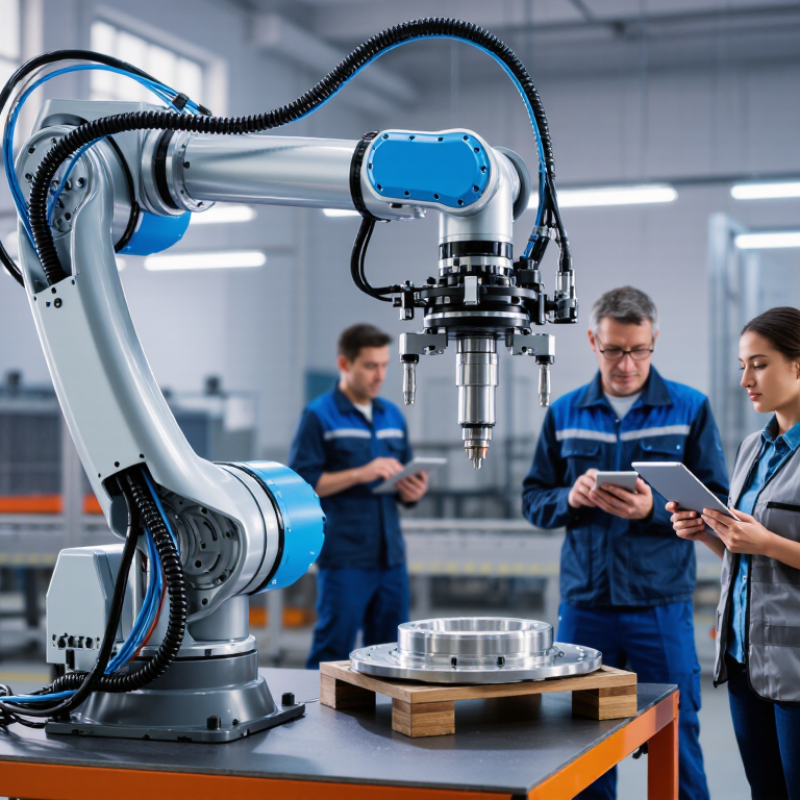
Choosing a robot arm should begin with payload, not reach or software features. The UR3e–UR30 capacity range provides a useful starting point: approximately 3 kg, 5 kg, 7 kg, 12.5 kg, 16 kg, 20 kg, and 30 kg across suitable models. These figures describe rated payload, not the weight available for your part alone. The gripper, adapter plate, cables, and sensors consume part of that allowance.
Leave a safety margin.
In a practical cell review, calculate the complete moving load first. A 4 kg part may require a 6 kg payload rating after adding a 1.2 kg gripper and tooling. Wrist torque can become the real limitation, especially when the load sits 200 mm from the flange. Reach, speed, acceleration, and mounting angle also change performance. A heavier arm may appear safer, yet it can occupy more space and increase cycle time. That trade-off is easy to miss.
Check the manufacturer’s current capacity and moment specifications before purchase. Test the heaviest part, the most extended grip, and the fastest planned motion. Data sheets are reliable, but factory conditions rarely match them perfectly. Packaging tolerances, suction loss, or an underestimated cable bundle can disturb the calculation. I would rather revise the tool design early than discover vibration beside a production line. The correct choice is the model that handles the real payload consistently, not merely the model with the largest number.
Match Workspace Requirements with UR Reach Specifications
How to Choose a UR Robot Arm for Your Application?
Reach specifications should be matched to the real workspace, not the workbench drawing. Measure the farthest pick point, fixture edge, conveyor height, and tool length. Then add clearance for wrist rotation and cable movement. A robot listed with 900 mm of reach may not safely cover a 900 mm radius in practice.
I have seen layouts fail because engineers measured from the robot base only. The gripper extended beyond the rated envelope. A simple mistake. Use the tool center point as the reference, and test every required pose in a digital model. Keep a practical reserve of 10% to 20% when space allows. This reserve helps with fixture changes, operator access, and unexpected collision risks. Payload also changes reach performance, especially when the tool is long or offset.
The International Federation of Robotics reported 541,302 industrial robots installed worldwide in 2023, with 4.28 million operating globally in its World Robotics 2024 report. This growth reflects wider automation adoption, but it does not remove application-specific checks. Select an arm whose reach covers the full task envelope, while its payload, repeatability, and mounting options suit the process. A longer arm is not automatically better. It can increase footprint, cost, and deflection. Recheck the layout with the actual end effector. The spreadsheet may still be wrong.
How to Choose a UR Robot Arm for Your Application? - Match Workspace Requirements with UR Reach Specifications
| Application Type |
Typical Workspace Requirement |
Recommended Reach |
Approx. Theoretical Workspace Diameter |
Typical Payload Range |
Recommended Installation |
Selection Notes |
| Small Parts Assembly |
Compact workbench with short transfer distances |
500–700 mm |
1,000–1,400 mm |
3–5 kg |
Tabletop or bench-mounted |
Choose a short arm when all pick-and-place points are close to the robot base. This minimizes footprint and improves accessibility around compact fixtures. |
| Machine Tending |
Loading and unloading one machine within a defined cell |
700–900 mm |
1,400–1,800 mm |
5–12 kg |
Floor, pedestal, or side-mounted |
Allow additional reach for door clearance, chuck access, part presentation, and safe tool approach angles. |
| Packaging and Case Packing |
Repeated movement between conveyor, fixture, and carton |
900–1,300 mm |
1,800–2,600 mm |
5–12.5 kg |
Floor or elevated pedestal |
Longer reach can cover wider conveyor lanes and carton locations, but payload must include the gripper, sensors, and product weight. |
| Palletizing |
Multiple pallet positions with varying layer heights |
1,300–1,750 mm |
2,600–3,500 mm |
12–25 kg |
Floor-mounted near pallet area |
Verify wrist torque, vertical stroke, cycle time, and end-of-arm tooling mass in addition to the nominal payload rating. |
| Welding or Dispensing |
Long seams, curved paths, or large workpieces |
900–1,300 mm |
1,800–2,600 mm |
5–12 kg |
Floor, wall, or positioner-mounted |
Prioritize wrist orientation, cable routing, path accuracy, and collision clearance rather than reach alone. |
| Quality Inspection |
Camera or sensor access across a fixture or inspection table |
700–1,300 mm |
1,400–2,600 mm |
3–10 kg |
Bench, overhead, or side-mounted |
Use the minimum reach that covers every inspection point while maintaining the required sensor distance and viewing angle. |
| Large-Part Handling |
Wide fixtures, multiple stations, or deep machine access |
1,300–1,750 mm |
2,600–3,500 mm |
10–25 kg |
Floor or elevated pedestal |
Check deflection, stopping distance, base rigidity, and payload performance at maximum horizontal extension. |
Workspace Matching Formula:
Theoretical workspace diameter is approximately twice the nominal reach. For practical cell design, reserve additional clearance for the robot base, elbow movement, tooling, fixture geometry, cable routing, and safety limitations. A useful preliminary target is to select a reach that exceeds the farthest required working point by approximately 10–20%.
Check Safety Compliance Against ISO 10218-1 and ISO/TS 15066
How to Choose a UR Robot Arm for Your Application?
Safety compliance should guide your robot arm selection, not follow it. Check whether the arm supports the safety requirements of ISO 10218-1. This standard addresses robot design, protective measures, stopping functions, and safe integration. However, compliance is not only a supplier’s responsibility. Your finished cell needs a documented risk assessment.
For collaborative applications, review ISO/TS 15066 carefully. It provides guidance for human-robot contact, power, force, speed, and separation monitoring. A lightweight arm is not automatically safe. Payload, tool shape, gripping force, workpiece edges, and operating speed can change the risk. Test realistic movements, including awkward reaches and unexpected stops. In practice, a soft part can still hurt when accelerated quickly. This detail is easy to miss.
Tips:
Ask for the declaration, safety-function data, and applicable test evidence. Verify emergency stops, protective stops, enabling devices, and reduced-speed modes. Measure stopping distance on your actual floor and with your actual load. Do not rely on a factory demonstration. It may use different settings. Recheck the assessment after changing software, tools, payloads, or layout. A small programming update can create a new hazard. Also confirm the current standard editions and local workplace rules with a qualified safety professional. Mistakes happen, even in careful projects. Planning for review is better than assuming the first assessment is perfect.
Compare Repeatability, Cycle Time, and Required Throughput
Choosing a robot arm starts with the process, not the catalog. Repeatability tells you how closely the arm returns to the same programmed position. It does not guarantee absolute accuracy across the entire workspace. For a vision-guided pick, measure placement results at the actual conveyor height. A few millimeters can decide whether a gripper catches a rim or misses it. This detail is easy to underestimate.
Cycle time should be measured from complete cycle, including approach, gripping, retracting, and handoff. A quoted motion time may exclude pauses, sensor checks, and safety delays. Record at least 100 cycles under realistic payload and cable routing conditions. Then calculate average time, worst-case time, and stoppage frequency. If one cycle takes 12 seconds, theoretical throughput is 300 units per hour. Real output may be lower after changeovers, replenishment, and quality checks. Leave capacity in the plan.
Required throughput should match demand, takt time, and available operating hours. An arm achieving target speed at 95 percent utilization leaves little recovery room. Shop-floor trials often expose gripper slips and operator loading. The result can look impressive, but output remains inconsistent. Check repeatability after warm-up, tool changes, and several weeks of use. Also test the slowest product variant, not only the easiest one. A short pilot with logged data is more reliable than a polished demonstration.
How to Choose a UR Robot Arm for Your Application?
Compare repeatability, cycle time, and required throughput using representative industrial planning benchmarks.
Throughput is calculated as 3,600 seconds divided by cycle time, multiplied by an 85% operating availability factor. Select an arm whose repeatability is tighter than the process tolerance, whose cycle time meets the takt time, and whose practical throughput exceeds the required production rate.

 +91-97254 16844